Videos Destacados
Búsquedas Populares
Vistos Recientemente
Estados de Ánimo y Géneros
Autumn
Chill
Commute
Energize
Feel good
Focus
Gaming
Party
Romance
Sad
Sleep
Summer
Winter
Workout
African
Arabic
Blues
Bollywood & Indian
Classical
Country & Americana
Dance & electronic
Decades
Family
Folk & acoustic
German hip-hop
German pop
Hip-hop
Indie & alternative
J-Pop
Jazz
K-Pop
Latin
Mandopop & cantopop
Metal
Pop
R&B & soul
Reggae & caribbean
Rock
Schlager
Soundtracks & musicals
Mi Cuenta
Iniciar Sesión
Mis Listas de Reproducción
Mis Estadísticas
Subir
Blog
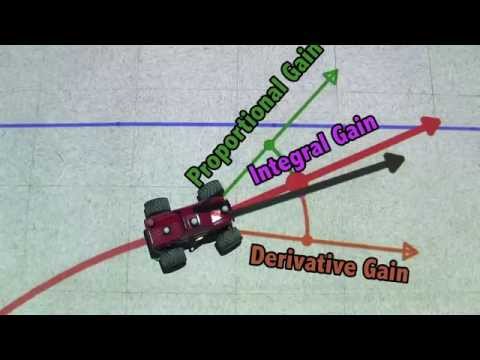
A* Path Planning Algorithm with a PID Controller
2:18
|
Procesando video...
Cargando...
Descargar
Siguiente Video
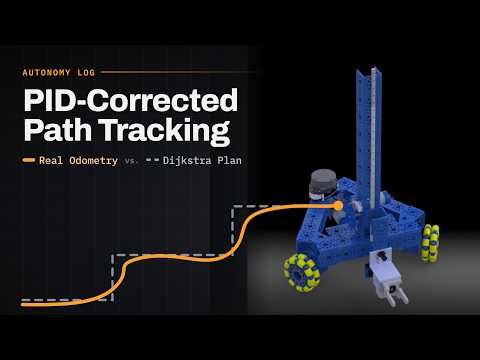
PID-Corrected Path Tracking: Real Odometry vs. the Dijkstra Plan
1:29
|
Videos Relacionados
1:29
PID-Corrected Path Tracking: Real Odometry vs. the Dijkstra Plan
0:18
[PythonRobotics] Path tracking simulation with LQR steering control and PID speed control.
0:23
Turtlebot Autonomous A* Path Planning with PID Control and Kalman Filter
4:41
Controlling Self Driving Cars
0:28
[PythonRobotics] Path tracking simulation with Stanley steering control and PID speed control.
0:17
[PythonRobotics] Path tracking with rear wheel feedback steering control and PID speed control
0:22
Global Path Planning vs Local Path Planning
3:27
Path planning (informed RRT*) , path following (pid controller) and wall follower on Turtelebot3
0:34
pid path planning
0:21
[PythonRobotics] Path tracking simulation with LQR speed and steering control.
0:39
[PythonRobotics] Path tracking simulation with pure pursuit steering control and PID speed control.
1:22
Longitudinal (PID) and Lateral (POP) Motion Control of Autonomous Vehicle
1:22
DWA(Dynamic Window Approach) Pioneer - PID Controller - SLAM -Navigation
5:45
Real-time Wheeled Robot Controller and Simulator using Wi-Fi & PID Algorithm with Odometry
1:24
Path Planning of Differential Drive robot using PID Control in Simulink
1:32
Longitudinal (PID) and Lateral (PID) Motion Control of Self-Driving Car
3:06
Proximally Optimal Predictive Control Algorithm for Path Tracking of Self Driving Cars